verifiedAIS-156 | UN38.3 | CE | IEC 62619 | 12-market export certification system
EN
TIANQIULi-ion Export
Commercial automotive-grade · open hardware and software platformCAN 2.0B / RS485 / J1939Official Vector .DBC supportOTA packages and SDK

BMS host software and communication protocol open centre:connect the vehicle VCU and cluster in 10 minutes

Built for the engineering pain points of overseas e-moped, light commercial and three-wheeler OEMs and retrofitters: no more black-box protocols that cannot be adapted, clusters that jump or fail to show charge, and protection thresholds locked out of reach. We supply an official no-rewire protocol mapping library and a plug-and-play industrial tuning environment.

dataset
Fully open DBCStandard Vector CANoe
tune
Modbus-RTUFull register address map
cell_tower
4G IoT relayRemote SOH calibration
phone_iphone
Dual-platform BLE appHandheld field tuning

verifiedCAN 2.0B extended frame · 29-bit identifier · CRC-8 / J1850 checking · 250k / 500k by hardware jumper or software

developer_boardBMS HOST PROTOCOLPROTOCOL
CAN baud rate250k / 500k bpsHardware jumper / software adaptive
Bus load< 21.8%Bidirectional with no dropped frames or congestion
Telemetry frame period100 msHeartbeat configurable (50 ~ 1000ms)
Checking schemeCRC-8 / J18500 dropped frames, error-tolerant redundancy
terminalLive RX frame · SOC / pack voltage0x1818D0F3 · SOC 100% / 53.4V
boltMax discharge / SOH0x181AD0F3 · 300A / 99%

Specification notice:Reference values only — batch and duty-cycle variation applies. Contact us for detailed specifications.

developer_boardBMS Host Protocol Bench

Host protocol status

Hardware interconnection testing follows ISO 11898 and SAE J1939 in-vehicle bus standards, so communication stays stable in complex electromagnetic environments and hot road conditions worldwide.

cable250k / 500k bpsCAN baud rateHardware jumper / software adaptive
speed< 21.8%Bus loadBidirectional, no dropped frames
schedule100 msTelemetry frame cycleHeartbeat configurable (50–1000ms)
fact_checkCRC-8 / J1850Checking mechanismZero frame-loss redundancy

Specification notice:The figures above are engineering reference values. They may differ with production batch, configuration and actual duty cycle, and the percentages for life, efficiency, availability and coverage are engineering estimates and bench references. Contact us for the detailed specification sheet.

sciencePROTOCOL TESTING

System software commissioning and protocol testing in practice

From online calibration and threshold tuning to differential signal quality and SOC algorithm validation — four development checkpoints backed by a senior powertrain electronics team.

tune

Online host calibration and protection thresholds

Live capture of cell voltage spread, MOSFET thermal drift and over-current / short-circuit thresholds, with on-site fine-tuning of over- and under-voltage protection delays.

CAN frame sample
monitor_heart

CAN_H / CAN_L differential signals

The oscilloscope captures rising and falling edges and common-mode immunity to satisfy the high-pulse environment of heavy cargo tricycles and commercial two-wheelers.

DEV 02 / ISO 11898-2
balance

Active balancing and SOC algorithm calibration

Coulomb counting plus extended Kalman filter (EKF) validation solves the charge-gauge jumping seen on tuk-tuks and e-motorcycles during long climbs and hard acceleration.

DEV 03 / SOC_ERR < 3%
support_agent

One-to-one protocol integration and joint debugging

Senior powertrain electronics engineers provide bilingual support, covering harness definitions and joint commissioning for clusters and vehicle VCUs.

DEV 04 / 1-ON-1 SUPPORT
downloadDeveloper Resource Matrix

Core host tools and communication development material

Updated to the 2026 Q1 release. Packs are delivered by encrypted corporate email or shipped with your engineering samples.

desktop_windows

TIANQIU official host configuration software (Windows x64)

v4.6.2 release · portable package · 38.4 MB

Reads and writes overcharge / over-discharge / short-circuit and over-current thresholds, calibrates cell voltage spread, exports fault history codes (DTC logs) and performs one-click OTA firmware updates.

Windows x64Portable packageDTC log export
schema

CAN 2.0B extended-frame protocol specification + Vector CANoe .DBC database

Rev 3.8 · DBC & PDF · 4.2 MB

Defines total voltage, instantaneous charge/discharge current, highest and lowest cell index and temperature frames. Loads directly into CANoe for simulation and is parsed immediately by the vehicle cluster.

Vector .DBC29-bit extended frameCANoe simulation
integration_instructions

RS485 / Modbus-RTU register map with C / Python debug examples

Standard V2.4 · Source Code · 12.8 MB

Fits mainstream industrial gateways, remote DTUs and Siemens / Schneider PLCs. Includes a complete CRC16 checksum library and working code for the common function codes (0x03 / 0x06 / 0x10).

Modbus-RTUC / Python examplesCRC16 library
cloud_sync

Overseas 4G-IoT swap and fleet cloud platform MQTT / HTTP API manual

Cloud SDK v1.9 · API Spec · 8.1 MB

Lets swap operators in Africa and Southeast Asia connect to their own servers. Provides live GPS tracks, battery charge/discharge cycle counts and an interface to issue remote power-off and immobilisation commands.

MQTT / HTTPOwn-server connectionRemote immobilisation
electric_bolt

No-rewire match patch pack for mainstream commercial controllers (FarDriver / Kelly / Sabvoton / Votol)

Pack 2026 · Config Patch · 6.5 MB

Presets current limiting, field-weakening speed increase and regenerative braking curves for mainstream controllers, removing physical harness jumpers — load the preset directly from the host software.

FarDriverKellySabvotonVotol
engineeringStandard Operating Procedure

BMS tuning and full vehicle bus commissioning in three steps

A standard industrial configuration flow that shortens vehicle prototyping and on-site after-sales diagnosis dramatically.

  1. 01cable

    Physical hardware connection

    Use the TIANQIU isolated USB-to-CAN / 485 adapter box and connect to the pack external aviation comms plug or debug port, making sure the shield is reliably grounded.

    Self-recovering opto-isolation protection (1500VDC)
  2. 02monitor_heart

    Host handshake and status capture

    Launch the host software and click “auto-scan baud rate”. The software identifies the battery hardware version and cell count automatically, then reads current cell voltages, temperatures and alarm history.

    Automatically matches 250k / 500k protocol templates
  3. 03verified_user

    Duty-cycle parameter calibration and download

    For different national road conditions (Kenyan hot gradients, Philippine heavy loads), send continuous and peak over-current thresholds and the regenerative cut-off, then burn and lock them into EEPROM with one click.

    Dual-check confirmation prevents mis-writes and supports rollback
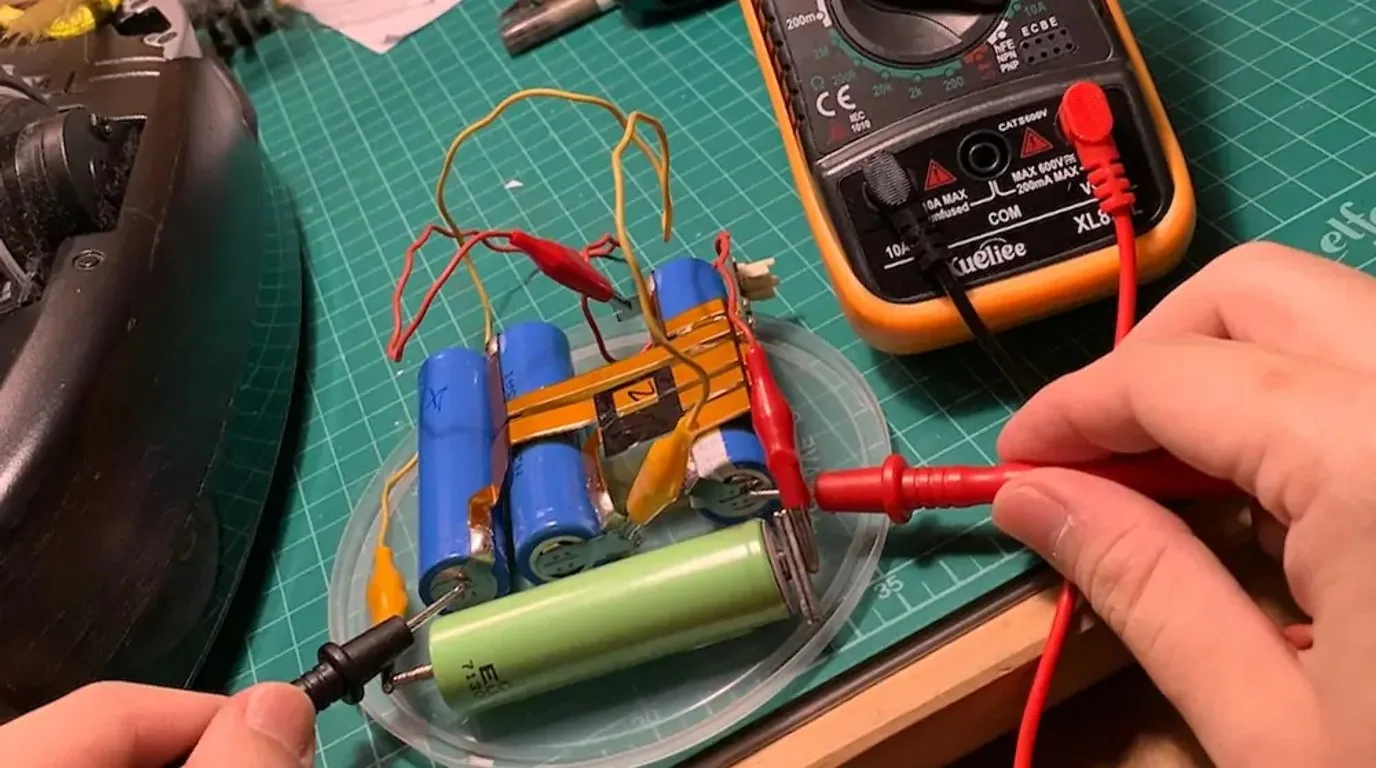
Battery diagnostic analyser showing cell balancing curves and SOC data
phone_iphoneField Commissioning Tools

Field tuning and no-rewire controller matching

Parameters can still be changed on site without a laptop: every commercial motive pack carries an industrial BLE 5.0 module and ships with no-rewire patch packs for mainstream controllers.

BLE 5.0 field tuningCAN 2.0B 250k / 500kIsolated RS485 Modbus-RTU4G-IoT MQTT cloud
  • Phone-based field tuning: overseas engineers install the official “TIANQIU BMS Tool” app (Android / iOS), scan the QR code on the enclosure to connect, then view cell voltage spread, export CSV logs and adjust charge/discharge protection delays within safe permissions.
  • No-rewire controller patch pack: preset current limiting, field-weakening speed increase and regenerative braking curves for FarDriver, Kelly, Sabvoton and Votol controllers load straight from the host software, removing physical harness jumpers.
  • Isolated communication adapter: the isolated USB-to-CAN / 485 adapter box provides 1500VDC self-recovering opto-isolation, connecting to the pack external aviation comms plug or debug port with the shield reliably grounded.
tuneProtocol & Register Reference

Physical-layer parameters and register / function-code reference

These are the physical-layer parameters behind auto-scan and protocol template matching, together with the RS485 / Modbus-RTU register and function-code conventions.

ISO 11898-2 · SAE J1939
ItemParameter / valueNote
CAN baud rate250k / 500k bpsHardware jumper or software adaptive; one-click auto-scan from the host
Bus load< 21.8%Bidirectional, no dropped-frame congestion
Telemetry frame cycle100 msHeartbeat configurable (50–1000ms)
Checking mechanismCRC-8 / J1850Zero frame-loss redundancy
CAN 2.0B extended frame29-bit identifierISO 11898-2 compliant; loads directly into a Vector CANoe .DBC database
RS485 / Modbus-RTU function codes0x03 / 0x06 / 0x10Register read/write and batch download, with a complete CRC16 checksum library
Debug hardware protection1500VDC self-recovering opto-isolationUSB-to-CAN / 485 adapter box with the shield reliably grounded

Example host frame samples: 0x1818D0F3 [SOC 100%, Pack 53.4V] · 0x1819D0F3 [Cell Diff 3mV, Temp 26℃] · 0x181AD0F3 [Max Dischg 300A, SOH 99%]. The same frame and register definitions apply to the cluster and 4G IoT integration described in the commercial BMS and CAN bus guide.

Specification notice:The figures above are engineering reference values. They may differ with production batch, configuration and actual duty cycle, and the percentages for life, efficiency, availability and coverage are engineering estimates and bench references. Contact us for the detailed specification sheet.

photo_libraryField & Lab Evidence

Field and laboratory evidence

Production-line, laboratory and field photographs for this subject. Original records and third-party reports can be released for your project on request.
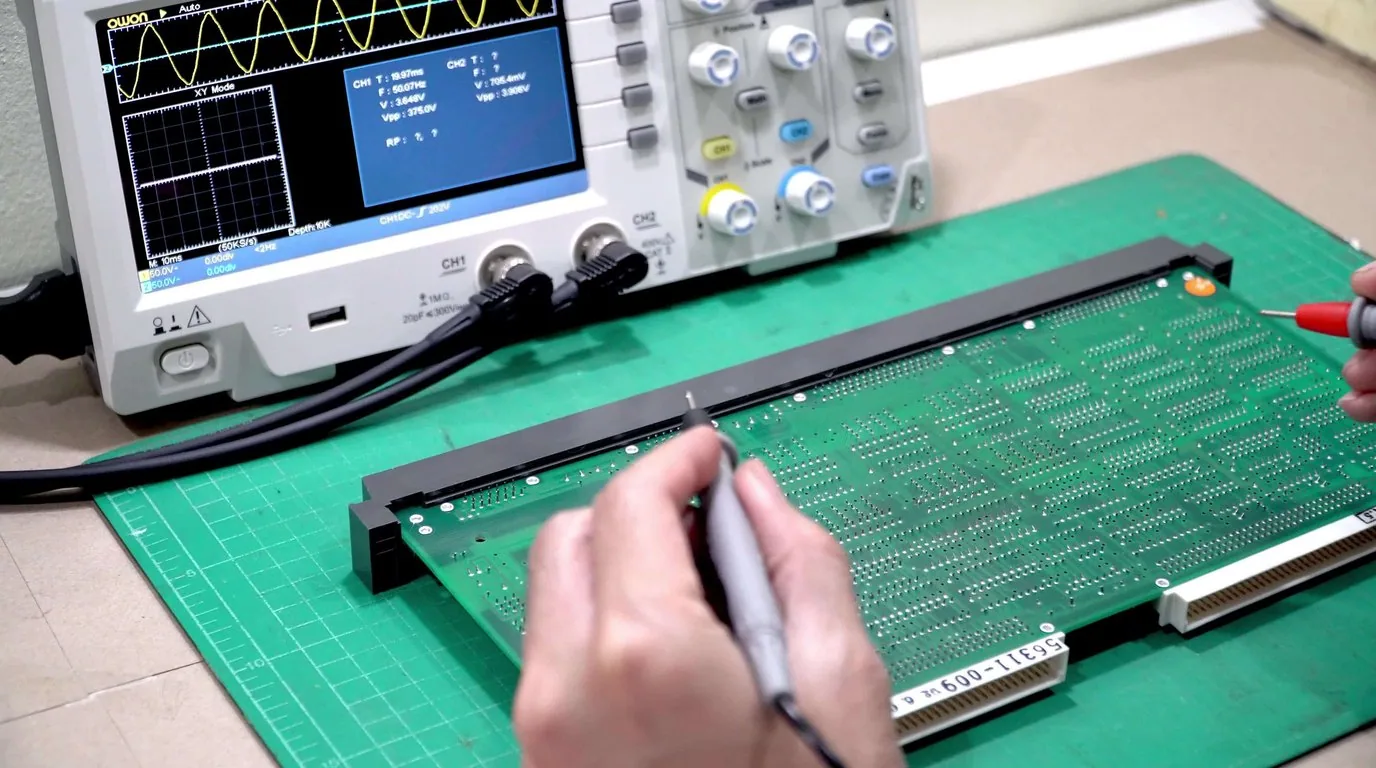
Smart BMS circuit board on a workbench
Battery diagnostic analyser showing cell-voltage balancing curves
Engineering consultation desk reviewing battery system drawings
helpTroubleshooting & Questions

Common protocol integration and host software questions

1. The vehicle cluster does not show charge, or the value jumps. Can the host software fix it?expand_more
The usual cause is that the broadcast ID the cluster expects differs from the BMS default (for example 0x1818D0F3 versus 0x18F001F0). Open the bus protocol mapping page in the host software and switch the SOC frame byte offset from little-endian to big-endian, or simply load the preset “general passenger three-wheeler cluster template” — no change to the cluster hardware is needed.
2. How do we change discharge parameters on an e-moped or three-wheeler on site with no laptop?expand_more
Every TIANQIU commercial motive pack has an industrial BLE 5.0 module built in. An overseas engineer installs the official “TIANQIU BMS Tool” app (Android / iOS), scans the QR code on the enclosure to connect, and can then view cell voltage spread, export CSV logs and adjust charge/discharge protection delays within safe permissions.
3. What normally causes “CAN communication timeout / severe packet loss” when the host connects?expand_more
First check that a 120Ω terminator is fitted at the end of the bus (missing or double-paralleled terminators cause signal reflection). Second, confirm the spacing between the controller high-voltage bus and the CAN differential twisted pair is greater than 10cm. Finally, confirm the host adapter driver is the official isolated version, and enable the hardware common-mode surge filter switch where strong motor start-stop interference is present.
4. Vector CANoe reports errors or cannot parse signals after loading the official .DBC file. How is that fixed?expand_more
Check your CANoe project version. The TIANQIU DBC file follows the CAN 2.0B extended-frame standard (29-bit identifier). In the CANoe network hardware configuration set Baudrate to 250kbps and Sample Point to 80%, and make sure “force standard 11-bit frame” is not ticked on import — Pack_Voltage, Cell_Max_V, Discharge_Limit and the full signal set will then display correctly.
5. Do you support customer-built swap stations or two- and three-wheeler fleet management platforms?expand_more
Fully. We publish an open MQTT / HTTP interface specification. With the optional 4G-IoT module, packs can point data directly at the IP and port of a customer’s own server so the data is not locked into a third-party platform, and we supply complete JSON decoding examples (Node.js / Java / Python).
6. How long does a private protocol customisation for a specific controller take?expand_more
Where the customer uses an existing protocol matrix (common Kelly, FarDriver or Weiyuan units), we can issue test firmware within 24 hours. For a fully private vehicle VCU protocol, once the customer provides the protocol requirements document and frame cycle definitions the software team typically completes code compilation and HIL bench simulation validation and delivers the firmware package within 3–5 working days.
engineeringEngineering Response

Request your protocol development pack and engineering support (reply within 24 hours on working days)

If you need custom control logic, unpublished controller calibration parameters, or an engineer to assist remotely with commissioning, submit your project requirements and our engineering team will make contact within 24 hours on working days.

  • Free one-to-one protocol analysis and harness pin-out definition drawings
  • Custom OEM-branded host software and dedicated installer packages
  • Bilingual senior bus engineers available for live joint commissioning
mailEngineering desk: sales@erickshawtrikebattery.com
callTechnical hotline / WhatsApp: +86 13922702227
location_onEBattery Office, Room 310I, Huilange BLDG, No. 273, Huangpu Blvd W, Tianhe District, Guangzhou 510620, Guangdong, China
verifiedOnce accepted, the resource pack is sent straight to your inboxscheduleAn engineering expert adds your contact within 24 hours on working days to assistlockProtocol trade secrets strictly protected; NDA available first

Specification notice:The figures above are engineering reference values. They may differ with production batch, configuration and actual duty cycle, and the percentages for life, efficiency, availability and coverage are engineering estimates and bench references. Contact us for the detailed specification sheet.

lockProtected by NDA

Engineering protocol trade secrets are strictly protected: the controller brand, protocol documents and vehicle data you submit are used only for this project’s commissioning and are never disclosed to third parties.